Материал: part17

Внимание! Если размещение файла нарушает Ваши авторские права, то обязательно сообщите нам

Page 556​

DICOM PS3.17 2020a - Explanatory Information​

FFF.2.5.1.3.4 X-Ray Field of View Macro Recommendations​

The usage of this macro is recommended to specify the characteristics of the field of view.​

The field of view characteristics may change per-frame across the Multi-frame Image.​

FFF.2.5.1.3.5 X-Ray Isocenter Reference System Macro Recommendations​

The usage of this macro is recommended to specify the fixed reference system of the acquisition geometry.​

FFF.2.5.1.3.6 X-Ray Geometry Macro Recommendations​

The usage of this macro is recommended to specify the distances between the X-Ray source, isocenter and X-Ray detector.​

FFF.2.5.1.3.7 XA/XRF Frame Pixel Data Properties Macro Recommendations​

The usage of this macro is recommended to specify the dimensions of the pixels at the image reception plane.​

FFF.2.5.1.4 Example​

In this example, the operator identifies the position (i, j) of an object of interest projected on the stored pixel data of an image A, and​ estimates the magnification of the conic projection by a calibration process.​

The operator wants to know the position of the projection of such object of interest on a second image B acquired under different​ geometry.​

The Attributes that define the geometry of both images A and B are described in the following figure:​

- Standard -​

DICOM PS3.17 2020a - Explanatory Information​

Page 557​


Image A

Image B


...


= 850

= 1000

Rows

(0028,0010)


= 850

= 1000

Columns

(0028,0011)


...


= DIGITAL_DETECTOR

= DIGITAL_DETECTOR

X-Ray Receptor Type

(0018,9420)


= CARM

= CARM

Positioner Type

(0018,1508)


= YES

= YES

C-Arm Positioner Tabletop Relationship

(0018,9474)


...


= 1.0\1.0

= 2.0\2.0

Detector Binning

(0018,701A)


= 0.2\0.2

= 0.2\0.2

Detector Element Spacing

(0018,7022)


= RECTANGLE

= RECTANGLE

Detector Active Shape

(0018,7024)


= 400.0\400.0

= 400.0\400.0

Detector Active Dimension(s)

(0018,7026)


= 25.0\25.0

= 25.0\25.0

Detector Active Origin

(0018,7028)


= 410.0\410.0

= 410.0\410.0

Physical Detector Size

(0018,9429)


=1024.5\1024.5

=1024.5\1024.5

Position of Isocenter Projection

(0018,9430)


...


Per-Frame Functional Groups Sequence

(5200,9230)


...


Item 1


>Field of View Sequence

(0018,9432)


Item 1


>>Field of View Shape

(0018,1147)

= RECTANGLE

= RECTANGLE


>>Field of View Dimensions in Float

(0018,9461)

= 170.0\170.0

= 400.0\400.0


>>Field of View Origin

(0018,7030)

= 600.0\600.0

= 25.0\25.0


>>Field of View Rotation

(0018,7032)

= 90

= 180


>>Field of View Horizontal Flip

(0018,7034)

= YES

= YES


>Frame Pixel Data Properties Sequence

(0028,9443)


Item 1


>>Imager Pixel Spacing

(0018,1164)

= 0.2\0.2

= 0.4\0.4


>Isocenter Reference System Sequence

(0018,9462)


Item 1


= 60.0

= -30.0


>>Positioner Isocenter Primary Angle

(0018,9463)


= 20.0

= 0.0


>>Positioner Isocenter Secondary Angle

(0018,9464)


= 0.0

= 0.0


>>Positioner Isocenter Detector Rotation Angle

(0018,9465)


>>Table X Position to Isocenter

(0018,9466)

= 10.0

= 20.0


= 30.0

= 100.0


>>Table Y Position to Isocenter

(0018,9467)


= 100.0

= 0.0


>>Table Z Position to Isocenter

(0018,9468)


>>Table Horizontal Rotation Angle

(0018,9469)

= -10

= 0.0


= 0.0

= 10.0


>>Table Head Tilt Angle

(0018,9470)


>>Table Cradle Title Angle

(0018,9471)

= 0.0

= 0.0


>X-Ray Geometry Sequence

(0018,9476)


Item 1


>>Distance Source to Isocenter

(0018,9402)

= 780.0

= 800.0


>>Distance Source to Detector

(0018,1110)

= 1300.0

= 1000.0


Figure FFF.2.5-1. Attributes of the example of tracking an object of interest on multiple 2D images​

The following steps describe the process to calculate the position (i, j)B of the projection of the object of interest in the Pixel Data of​ the image B, assuming that (i, j)A is known and is the offset of the projection of the object of interest from the TLHC of the Pixel Data​ of the image A, measured in pixels of the Pixel Data matrix as a column offset "i" followed by a row offset "j". TLHC is defined as (0,0).​

Step 1: Calculate the point (i, j)A in FOV coordinates of the image A.​

Step 2: Calculate the point (i, j)A in physical detector coordinates of the image A.​

Step 3: Calculate the point (Pu, Pv)A in positioner coordinates of the image A.​

Step 4: Calculate the point (PXp, PYp, PZp)A in positioner coordinates of the image A.​

Step 5: Calculate the point (PX, PY, PZ)A in Isocenter coordinates of the image A.​

Step 6: Calculate the point (PXt, PYt, PZt)A in Table coordinates of the image A.​

Step 7: Calculate the point (PXt, PYt, PZt)B in Table coordinates in mm of the image B.​

Step 8: Calculate the point (PX, PY, PZ)B in Isocenter coordinates in mm of the image B.​

Step 9: Calculate the point (PXp, PYp, PZp)B in positioner coordinates of the image B.​

- Standard -​

Page 558​

DICOM PS3.17 2020a - Explanatory Information​

Step 10: Calculate the point (Pu, Pv)B in positioner coordinates of the image B.​

Step 11: Calculate the point (i, j)B in physical detector coordinates of the image B.​

Step 12: Calculate the point (i, j)B in FOV coordinates of the image B.​

Step 13: Calculate the point (i, j)B in Pixel Data of the image B.​

In this example let's assume:​

(i, j)A = (310,122) pixels​

Magnification ratio = 1.3​

Step 1 : Image A: Point (i, j)A in FOV coordinates​

In this step, the FOV coordinates are calculated by taking into account the FOV rotation and Horizontal Flip applied to the FOV matrix​ when the Pixel Data were created:​

1.1: Horizontal Flip: YES​

new i = (columns -1) - i = 850 - 1 - 310 = 539​

new j = j = 122​

1.2: Image Rotation: 90 (clockwise)​

new i = j = 122​

new j = (columns -1) - i = 850 - 1 - 539 = 310​

(i, j)A = (122, 310) in stored pixel data.​

Step 2: Image A: Point (i, j)A in physical detector coordinates​

In this step, the physical detector coordinates are calculated by taking into account the FOV origin and the ratio between Imager Pixel​

Spacing and Detector Element Spacing:​

Di = Imager Pixel Spacing (column) = 0.2 mm​

Dj = Imager Pixel Spacing (row) = 0.2 mm​

Didet = Detector Element Spacing between two adjacent columns = 0.2 mm​

Djdet = Detector Element Spacing between two adjacent rows = 0.2 mm​

Zoom Factor (column) = Di / Didet = 1.0​

Zoom Factor (row) = Dj / Djdet = 1.0​

FOV Origin (column) = FOVidet = 600.0​

FOV Origin (row) = FOVjdet = 600.0​

new i = FOVidet + (i + (1 - Didet / Di) / 2) * Dj / Djdet = 600 + 122 * 1.0 = 722​ new j = FOVjdet + (j + (1 - Djdet / Dj) / 2) * Di / Didet = 600 + 310 * 1.0 = 910​

(i, j)A = (722, 910) in detector elements.​

Step 3: Image A: Point ( Pu, Pv)A in positioner coordinates​

In this step, the (Pu, Pv)A coordinates in mm are calculated from (i, j)A by taking into account the projection of the Isocenter in physical​ detector coordinates, and the Detector Element Spacing:​

- Standard -​

DICOM PS3.17 2020a - Explanatory Information​

Page 559​

ISO_Pidet = Position of Isocenter Projection (column) = 1024.5​

ISO_Pjdet = Position of Isocenter Projection (row) = 1024.5​

Didet = Detector Element Spacing between two adjacent columns = 0.2 mm​

Djdet = Detector Element Spacing between two adjacent rows = 0.2 mm​

Pu = (i - ISO_Pidet) * Didet = (722 - 1024.5) * 0.2 = -60.5 mm​

Pv = (ISO_Pjdet - j) * Djdet = (1024.5 - 910) * 0.2 = 22.9 mm​

( Pu, Pv)A = (-60.5, 22.9) in mm.​

Step 4: Image A: Point (PXp, PYp, PZp)A in positioner coordinates​

In this step, the positioner coordinates (PXp, PYp, PZp)A are calculated from (Pu, Pv)A by taking into account the magnification ratio,​ the Distance Source to Detector and the Distance Source to Isocenter:​

SID = Distance Source to Detector = 1300 mm​

ISO = Distance Source to Isocenter = 780 mm​

Magnification ratio = SID / (ISO - P Yp ) = 1.3​

PYp = ISO - SID / 1.3 = 780 - 1300/1.3 = -220 mm​

PXp = Pu / Magnification ratio = -60.5 / 1.3 = -46.54 mm​

PZp = Pv / Magnification ratio = 22.9 / 1.3 = 17.62 mm​

(PXp, PYp, PZp)A = (-46.54, -220, 17.62) in mm.​

Step 5: Image A: Point (PX, PY, PZ)A in Isocenter coordinates​

Inthisstep,theisocentercoordinates(PX,PY,PZ)A arecalculatedfromthepositionercoordinates(PXp,PYp,PZp)A bytakingintoaccount​ the positioner angles of the image A in the Isocenter coordinate system:​

Ap1 = Positioner Isocenter Primary Angle = 60.0 deg​

Ap2 = Positioner Isocenter Secondary Angle = 20.0 deg​

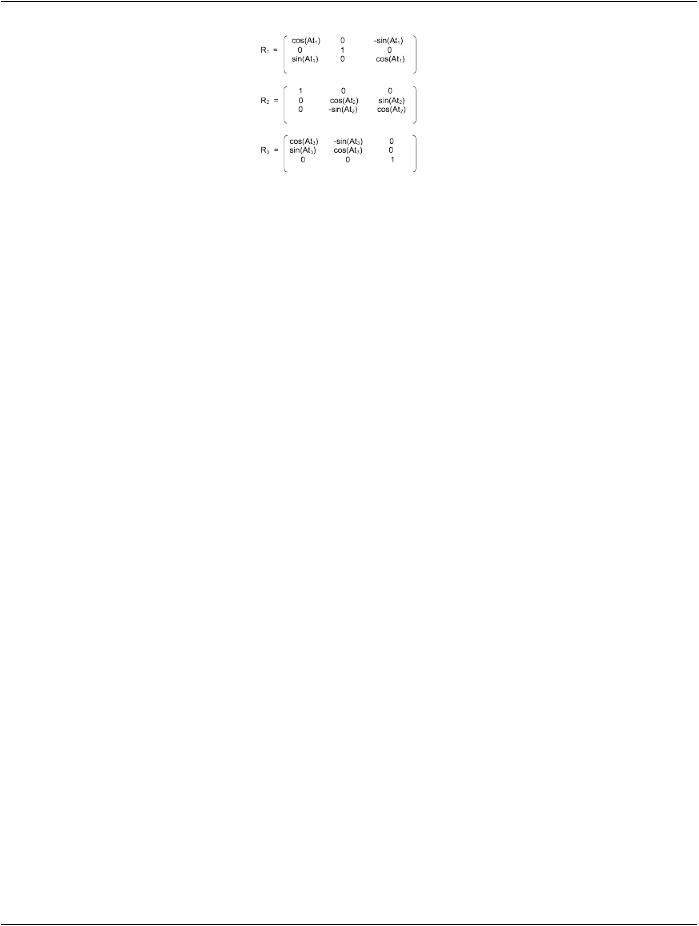
Ap3 = Positioner Isocenter Detector Rotation Angle = 0.0 deg​ (PX, PY, PZ)T= (R2 ·R1)T·(R3 T·(PXp, PYp, PZp)T)​

(PX, PY, PZ)A = (150.55, -65.41, 91.80) in mm.​

Step 6: Image A: Point (PXt, PYt, PZt)A in Table coordinates​

In this step, the table coordinates (PXt, PYt, PZt)A are calculated from the isocenter coordinates (PX, PY, PZ)A by taking into account​ the table position and angles of the image A in the Isocenter coordinate system:​

Tx =Table X Position to Isocenter = 10.0 mm​

Ty =Table Y Position to Isocenter = 30.0 mm​

Tz =Table Z Position to Isocenter = 100.0 mm​

At1 = Table Horizontal Rotation Angle = -10.0 deg​

At2 = Table Head Tilt Angle = 0.0 deg​

At3 = Table Cradle Tilt Angle = 0.0 deg​

- Standard -​

Page 560​

DICOM PS3.17 2020a - Explanatory Information​

(PXt, PYt, PZt)T= (R3 · R2 · R1) · ((PX, PY, PZ)T- (TX, TY, TZ)T)​

(PXt, PYt, PZt)A = (136.99, -95.41, -32.48) in mm.​

Step 7: Image B: Point (PXt, PYt, PZt)B in Table coordinates​

In this step, the table has moved from image A to image B. The table coordinates of the object of interest are the same on image A​ and image B because it is assumed that the patient is fixed on the table.​

(PXt, PYt, PZt)B = (136.99, -95.41, -32.48) in mm.​

Step 8: Image B: Point (PX, PY, PZ)B in Isocenter coordinates​

In this step, the isocenter coordinates (PX, PY, PZ)B are calculated from the table coordinates (PXt, PYt, PZt)B by taking into account​ the table position and angles of the image B in the Isocenter coordinate system:​

Tx =Table X Position to Isocenter = 20.0 mm​

Ty =Table Y Position to Isocenter = 100.0 mm​

Tz =Table Z Position to Isocenter = 0.0 mm​

At1 = Table Horizontal Rotation Angle = 0.0 deg​

At2 = Table Head Tilt Angle = 10.0 deg​

At3 = Table Cradle Tilt Angle = 0.0 deg​

(PX, PY, PZ)T= (R3 · R2 · R1)T· (PXt, PYt, PZt)T+ (TX, TY, TZ)T​

(PX, PY, PZ)B = (156.99, -12.11, -48.55) in mm.​

Step 9: Image B: Point (PXp, PYp, PZp)B in positioner coordinates​

Inthisstep,thepositionercoordinates(PXp,PYp,PZp)B arecalculatedfromtheisocentercoordinates(PX,PY,PZ)B bytakingintoaccount​ the positioner angles of the image B in the Isocenter coordinate system:​

Ap1 = Positioner Isocenter Primary Angle = -30.0 deg​

Ap2 = Positioner Isocenter Secondary Angle = 0.0 deg​

Ap3 = Positioner Isocenter Detector Rotation Angle = 0.0 deg​

(PXp, PYp, PZp)T= R3 · ((R2 · R1) · (PX, PY, PZ)T)​

(PXp, PYp, PZp)B = (142.01, 68.00, -48.55) in mm.​

Step 10: Image B: Point ( Pu, Pv)B in positioner coordinates​

In this step, the (Pu, Pv)B coordinates in mm are calculated from the positioner coordinates (PXp, PYp, PZp)B by taking into account​ the Distance Source to Detector and the Distance Source to Isocenter of the image B:​

- Standard -​

Источник: https://studfile.net/preview/14585770/